
- D. Russell, R. Papallas, and M. Dogar "Online state vector reduction during model predictive control with gradient-based trajectory optimisation". International Workshop on the Algorithmic Foundations of Robotics (WAFR). 2024
- Z. Xu, R. Papallas, and M. Dogar "Physics-Based Object 6D-Pose Estimation during Non-Prehensile Manipulation". International Symposium on Experimental Robotics (ISER). 2023
- S. Wang, R. Papallas, M. Leonetti, and M. Dogar "Goal-Conditioned Action Space Reduction for Deformable Object Manipulation". IEEE International Conference on Robotics and Automation (ICRA). 2023
- D. Russell, R. Papallas, and M. Dogar "Adaptive approximation of dynamics gradients via interpolation to speed up trajectory optimisation". IEEE International Conference on Robotics and Automation (ICRA). 2023
- R. Papallas, and M. Dogar "To ask for help or not to ask: A predictive approach to human-in-the-loop motion planning for robot manipulation tasks". IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). 2022
- R. Papallas, and M. Dogar "Non-Prehensile Manipulation in Clutter with Human-In-The-Loop". IEEE International Conference on Robotics and Automation (ICRA). 2020
- W. Bejjani, R. Papallas, M. Leonetti, and M. Dogar "Planning with a Receding Horizon for Manipulation in Clutter Using a Learned Value Function". IEEE-RAS International Conference on Humanoid Robots (Humanoids). 2018
Artificial Intelligence
Intelligent Robotics
Robotic Manipulation
Motion Planning
Motion Control
Robot Perception
Biography
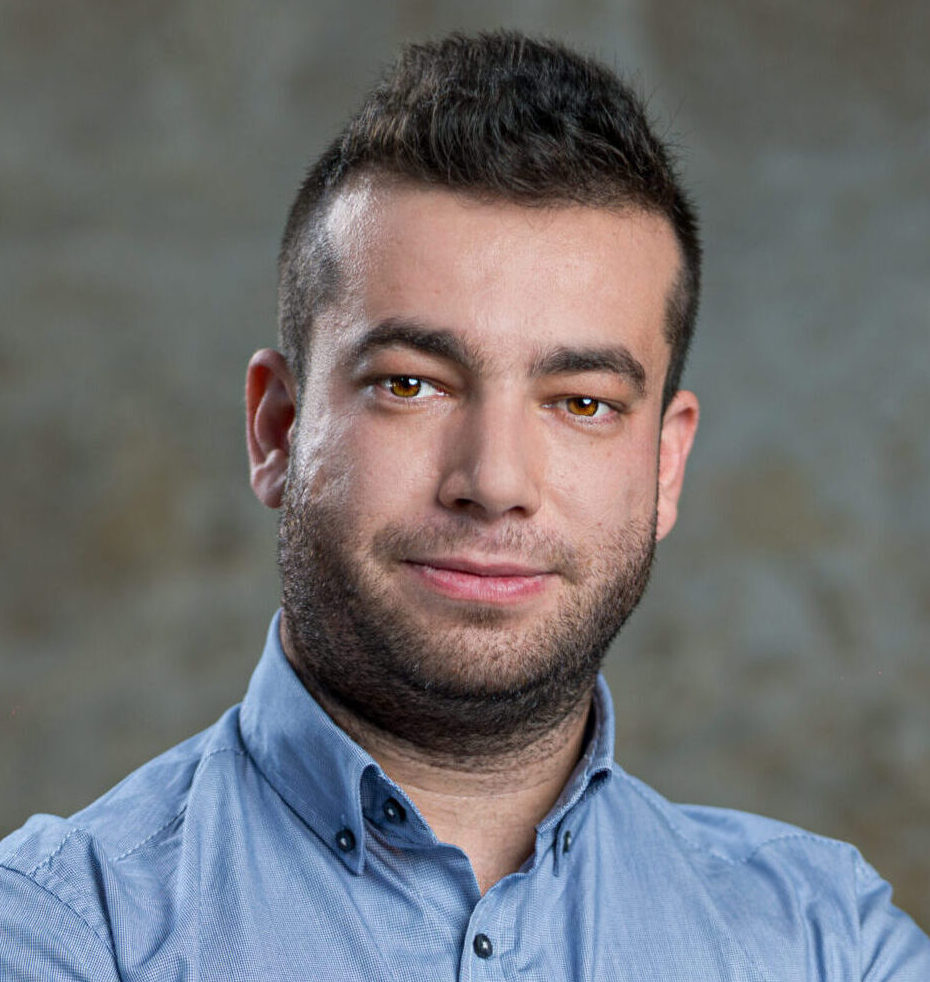
Dr Rafael Papallas holds a BSc in Computer Science (Industrial) with honors and a PhD in Artificial Intelligence and Robotics from the School of Computer Science at the University of Leeds, UK. From 2021 to 2024, he was a Research Fellow at the same institution. He is a recipient of the Alan Turing Post-Doctoral Enrichment Award from the Alan Turing Institute in the UK. Papallas also worked in industry as a Software Developer at ITI Group (previously Cimlogic), contributing to the development of advanced software systems. His research interests focus on intelligent robotics, particularly motion planning and physics-based robotic manipulation, with applications in home and service robotics as well as industrial domains such as warehouse automation and logistics.
Research
Papallas directs the Intelligent Robotics Research Lab at AUB Mediterraneo, which focuses on intelligent robotics and robotic object manipulation. This research area studies how robots, particularly robotic arms, can interact with their environment to achieve high-level tasks, such as opening doors, folding clothes, or retrieving objects. While humans perform such tasks effortlessly, enabling robots to do the same remains challenging.
The lab's work centers on four key challenges. First, perception: enabling robots to sense their environment, build reliable 3D representations, and identify objects in cluttered, partially occluded scenes. Second, motion planning: computing feasible and efficient actions in high-dimensional systems, often requiring interaction with the environment rather than simple collision avoidance. Third, physics-based manipulation: incorporating real-world dynamics into planning, while addressing the gap between simulation and reality and the computational cost of physics simulation. Finally, open-world manipulation: designing systems that can operate robustly in dynamic, unstructured environments with diverse objects and unpredictable conditions.
Overall, the lab develops algorithms and integrated systems that enable robots to solve real-world problems and augment human capabilities. You can learn more about this line of research here.
Teaching
Papallas is accredited by AdvanceHE as a Fellow of the Higher Education Academy (FHEA), in recognition of teaching excellence in higher education in the UK. He has delivered three Coursera courses to over 15,000 students worldwide (Python, Robotics and Cloud Computing). He teaches a number of courses at AUB Mediterraneo in Computer Science and Engineering.
Service
- 2026 Associate Editor for Visual Perception and Learning, IEEE International Conference on Robotics and Automation (ICRA) 2027.
- 2025 Lead Co-organizer of the Pafos Robotics Challenge
- 2025 Coordinator and member of the Research Committee.
- 2025 Member of the AI Policy Committee.
- 2023 Co-Organiser of the Workshop on Integrated Perception, Motion Planning and Control (IPPC), IROS, Detroit, USA.
Reviewer
- ISER International Symposium on Experimental Robotics
- CASE IEEE International Conference on Automation Science and Engineering
- IJRR The International Journal of Robotics Research
- RSS Robotics: Science and Systems
- RA-L IEEE Robotics and Automation Letters
- ICRA IEEE International Conference on Robotics and Automation
- IROS IEEE/RSJ International Conference on Intelligent Robots and Systems
- T-RO IEEE Transactions on Robotics
- ICAR IEEE International Conference on Advanced Robotics
- ISRR International Symposium of Robotic Research
- HRI ACM/IEEE International Conference on Human-Robot Interaction
Courses
Bachelor of Science in Computer Science and Engineering
- CSEN 100 — Introduction to Computer Science and Engineering
- CSEN 112L — Programming Laboratory
- CSEN 201 — Object Oriented Programming
- CSEN 214 — Algorithms and Data Structures
- CSEN 312 — Database Systems
- CSEN 401 — Artificial Intelligence
- CSEN 405 — Cloud Computing
- CSEN 406 — Autonomous Systems and Robotics
- CSEN 490 — Internship
- CSEN 499 — Capstone Project/Thesis
General Education
- INTD 100 — AI Literacy: Understanding Ourselves, Technology, and Society
Grants and Funding
- LINK — Co-PI, AUB/AUB Mediterraneo, June 1, 2026 – January 1, 2028, 25,000.00 Euro, AUB
- ERC Visiting Research Fellowship — Principal Investigator, Research & Innovation Foundation, May 1, 2026 – September 1, 2026, 31,300.00 Euro
- VISION ERC — Principal Investigator, Research & Innovation Foundation, June 1, 2025 – June 1, 2027, 100,000.00 Euro
Honors and Awards
- Alan Turing Post-Doctoral Enrichment Award — The Alan Turing Institute, 2023
Publications
Journal Articles
- Xu, Z., Papallas, R., Modisett, J., Billeter, M. and Dogar, M.R., 2025. Tracking and control of multiple objects during nonprehensile manipulation in clutter. IEEE Transactions on Robotics (T-RO), 41, pp.3929-3947.
- R. Papallas, A.G. Cohn, and M.R. Dogar, 2020. Online replanning with human-in-the-loop for non-prehensile manipulation in clutter—a trajectory optimization based approach. IEEE Robotics and Automation Letters, 5(4), pp.5377-5384.